
Robotics
Systems that act in the world the twin describes
A robot planning a path, allocating itself a task and reacting to a change is solving on hardware, in real time, the problem a simulation solves in a model. Robotics sits inside this company because those are the same problem approached from two ends, and because a twin's hardest ongoing problem is staying current.
The loop
Plan in the model, execute on the machine, correct the model
A twin’s hardest ongoing problem is staying current. An autonomous system moving through the modelled space is a way of keeping it so, and that is the commercial reason robotics sits inside this company rather than beside it.
The twin plans
Task allocation, routing, charging policy and traffic rules are decided against a model of the space and the workload, where a bad policy costs compute rather than a collision.
Simulation validates
Control logic runs in the loop against the model before hardware is committed. Deadlock at scale, contention at shared resources and the throughput cost of safety stops are all findable in simulation.
The robot executes
Perception, planning and control on the machine, in the physical space, under the conditions the model assumed.
Telemetry corrects the model
What the machine observed comes back. Where the operation has changed and the model has not, that difference is what the robot is best placed to find.
Capabilities
What exists, and at what stage
A robotics page is where an unlabelled claim does the most damage, so every line below carries its stage.
Robot and fleet simulation
Status: PrototypeRobot cells and mobile fleets with their control logic in the loop: kinematics, task times, traffic and deadlock, charging policy, task allocation and queueing at shared resources, with human presence and safety-driven stops included.
Perception, planning and control
Status: ResearchOn-device perception and autonomous behaviour in indoor environments. Under active development on the company's own hardware.
Telemetry as a twin input
Status: ResearchClosed-loop correction of an operational model from what an autonomous system observed. This is the direction the division exists for, and no deployment does it today.
Safety architecture
Status: AvailableSafety functions on deterministic hardware, separate from anything learned. This is an engineering and regulatory position rather than a preference, and it applies to every machine the company builds.
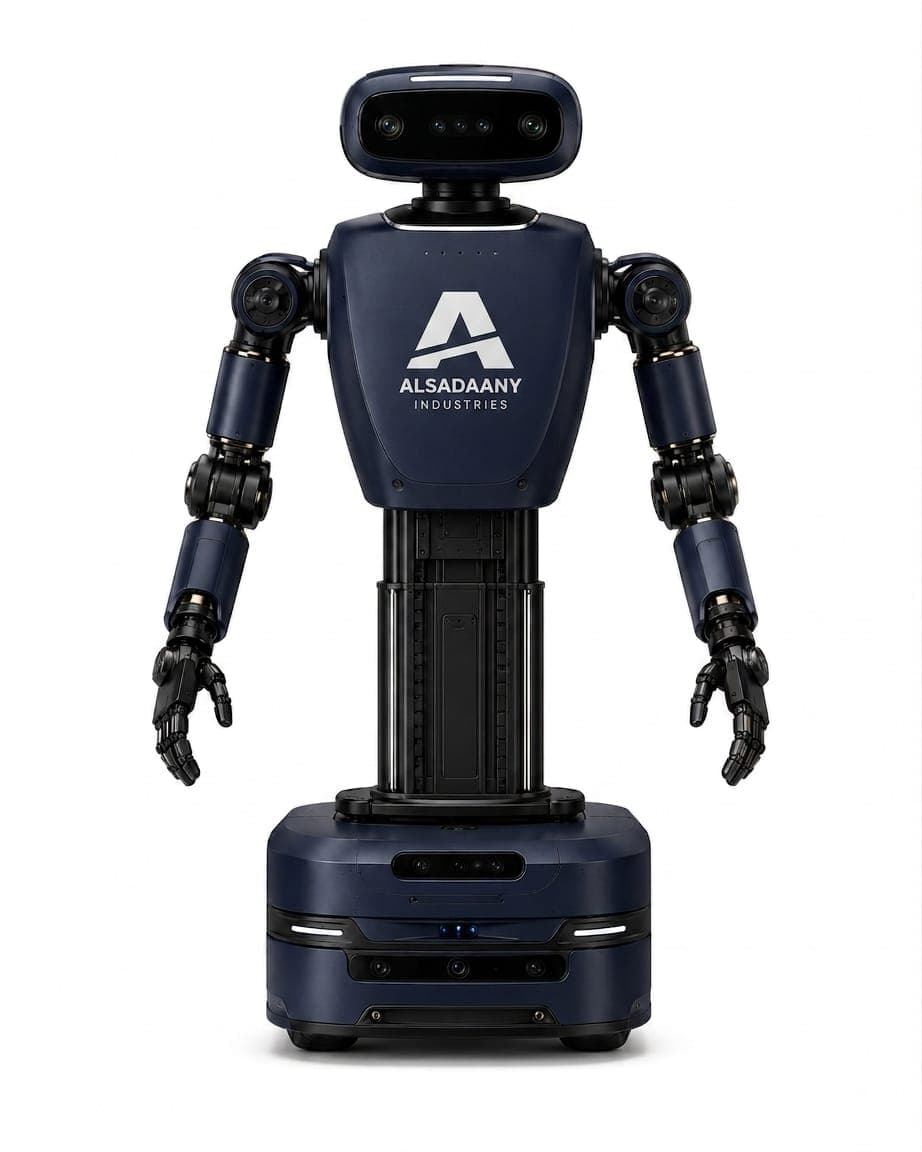
Alsadaany Robotics has one publicly announced product. Its specification, availability and price are published on its own site and are not duplicated here, so there is one authoritative source for the commercial terms of a machine.
Products
What the stack has shipped
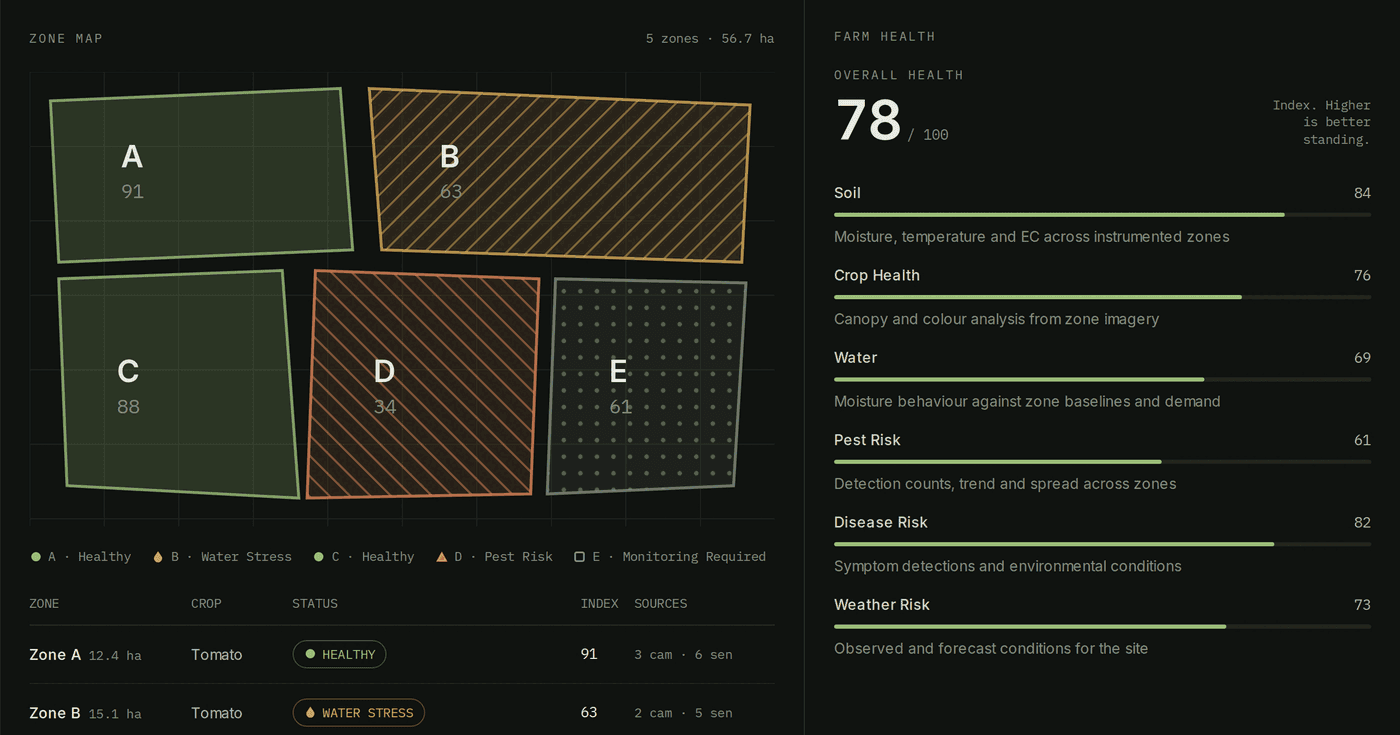
Three products built in-house, each with a site of its own. They are here because a company describing a technology stack should be able to point at what it has finished, and because each one is the same architecture applied at a different end of it.
Next step
Robots in an operation you already model
If you are deploying autonomous systems into a facility, the question of how many, under what policy, and at what throughput cost is a simulation question before it is a procurement one.
Prefer email? sales@alsadaany.com